Crazyflie Isaac Framework (CIF)
An open-source, modular NVIDIA Isaac Sim framework for Crazyflie research — DRL, multi-drone, benchmarking, and sim-to-real experimentation.

My research spans autonomous robotics, vision-based navigation, TinyML, embedded AI, and intelligent robotic systems. Below are selected research and engineering projects developed throughout my academic and industrial career.
An open-source, modular NVIDIA Isaac Sim framework for Crazyflie research — DRL, multi-drone, benchmarking, and sim-to-real experimentation.
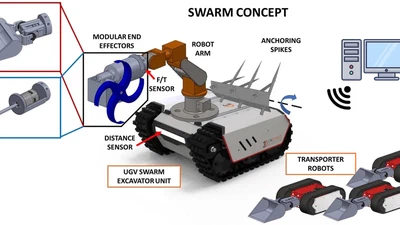
Autonomous robotic excavation system for tunnel construction using perception, manipulation, and mobile robotics.
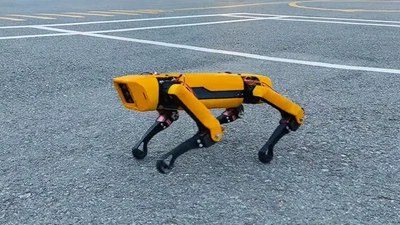
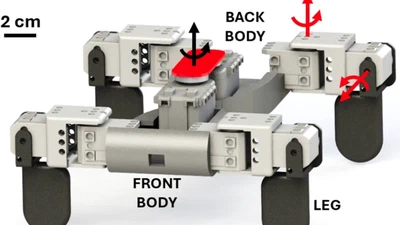
End-to-end design and development of a custom bio-inspired quadruped robotic platform.
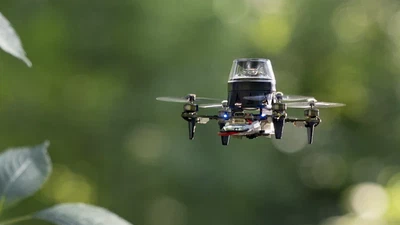
Vision-based autonomous navigation for resource-constrained nano drones.