Analyzing the Role of Spinal Joint Dynamics in the Movement of a Sprawling Robot
An analysis of how spinal joint dynamics shape the locomotion of a salamander-inspired sprawling robot.
merve-atasever
An analysis of how spinal joint dynamics shape the locomotion of a salamander-inspired sprawling robot.
A lightweight mapless navigation framework that enables resource-constrained micro robots to navigate safely in dynamic environments.
A hybrid locomotion framework combining biologically inspired Hildebrand gait design with deep reinforcement learning for salamander-inspired quadruped robots featuring active …
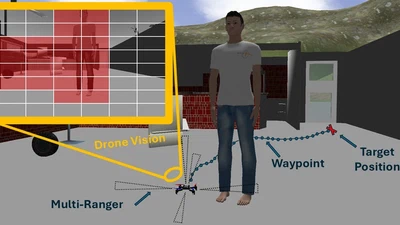
Lightweight multi-sensor perception and deep reinforcement learning framework for autonomous mapless navigation of resource-constrained tiny drones.
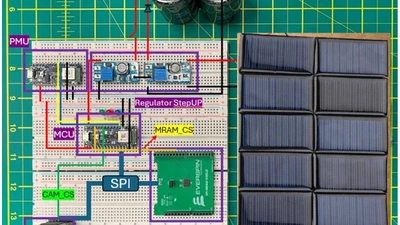
A solar-powered batteryless intelligent sensing framework for intermittent CNN inference and informative sample selection on energy-harvesting IoT devices.
A lightweight obstacle detection framework that converts images into compact grid representations and introduces temporal smoothing for robust real-time perception on …
An experimental evaluation of excavation tools for collective robotic soil excavation, highlighting key challenges and insights.
This work investigates autonomous soil excavation for tunnel-burrowing robots using an instrumented robotic manipulator. The study analyzes excavation forces, soil interaction, and …
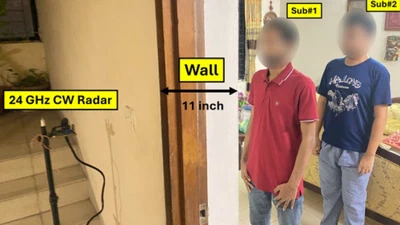
This work presents an integrated sensing and processing system for continuous-wave BioRadar, enabling non-invasive vital sign monitoring through embedded signal processing.