Crazyflie Isaac Framework (CIF)
An open-source, modular NVIDIA Isaac Sim framework for Crazyflie research — DRL, multi-drone, benchmarking, and sim-to-real experimentation.

An open-source, modular NVIDIA Isaac Sim framework for Crazyflie research — DRL, multi-drone, benchmarking, and sim-to-real experimentation.
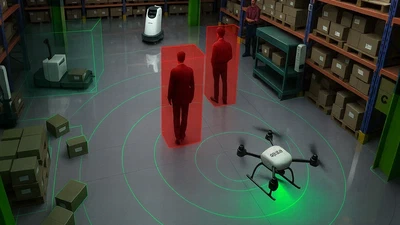
A universal end-to-end navigation framework that enables aerial and ground robots to navigate using vision and natural language instructions.
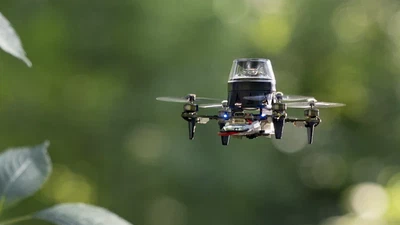
Vision-based autonomous navigation for resource-constrained nano drones.
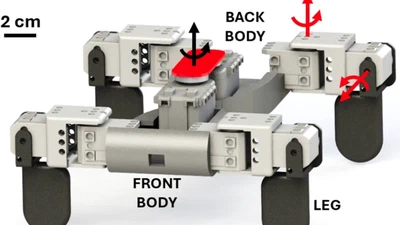
Deep reinforcement learning for bio-inspired quadruped locomotion.
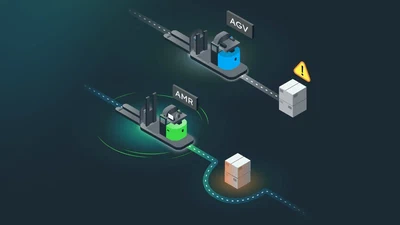
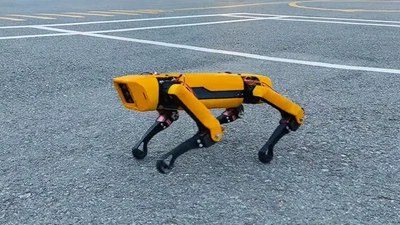
End-to-end design and development of a custom bio-inspired quadruped robotic platform.
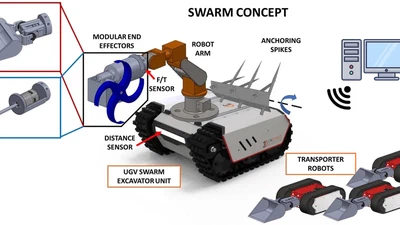
Autonomous robotic excavation system for tunnel construction using perception, manipulation, and mobile robotics.
Lightweight TinyML perception for resource-constrained edge platforms, including temporally consistent obstacle detection and energy-aware sensing.
Publish your data science and research directly from Jupyter Notebooks. No screenshots required.
Take full control of your personal brand and privacy by migrating away from the big tech platforms!